www.industryemea.com
26
'26
Written on Modified on
Humanoid Robot Industrial Training with Physical AI Models
NEURA Robotics & Technical University of Munich deploy 4NE1 Gen 4 at TUM RoboGym to accelerate automated manufacturing workflows.
neura-robotics.com
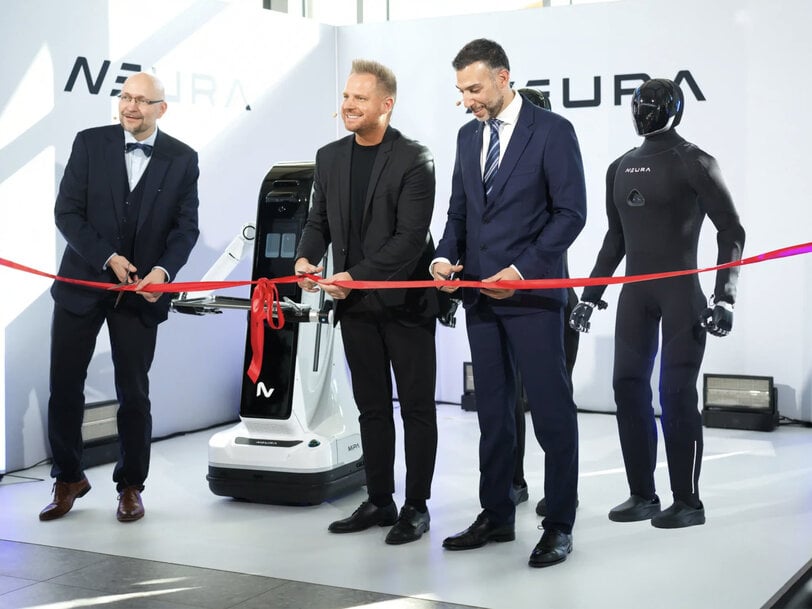
NEURA Robotics and the Technical University of Munich have established the TUM RoboGym at LabCampus near Munich Airport, deploying the humanoid robot 4NE1 Gen 4 alongside cognitive manipulators to train industrial automation skills. The joint facility serves manufacturing, automotive, logistics, and medical technology sectors by transferring physical process expertise into scalable machine learning architectures.
Industrial Challenge and Collaborative Framework
Industrial manufacturing processes require precise mechanical interactions, such as inserting fasteners, handling varying packaging materials, and managing complex assemblies. Traditional automated systems demand rigid programming for every operational shift, creating high integration costs for high-mix production environments.
To resolve this limitation, NEURA Robotics partnered with the Munich Institute of Robotics and Machine Intelligence at the Technical University of Munich under a three-year, 17 million euro joint development initiative. NEURA Robotics provides robotic hardware, operational personnel, and computing infrastructure backed by an 11 million euro investment, while the university contributes research facilities, engineering personnel, and algorithmic validation.
Physical AI Architecture and Data Collection
The testing ground utilizes a multimodal training architecture to train the proprietary Neuron AI perception-language-action foundation model. Sensor systems record physical force feedback, tactile interactions, kinematics, acoustics, and vision data across three operational streams:
Direct robotic execution captures real-time actuator responses and contact telemetry during production cycles. Human demonstrations utilize sensor-instrumented motion-capture suits and teleoperation rigs to translate manual craft techniques into numerical kinematic datasets. A digital simulation layer applies data amplification techniques to expose these motion profiles to parametric variations before validating them on physical machines. Connected via the Neuraverse network, trained models propagate across participating robotic nodes.
Hardware Specifications and Operational Testing
The humanoid platform 4NE1 Gen 4 operates as the primary testbed for series production integration. The unit features a structural mass reduction of 20 percent compared to its predecessor, utilizing a textile exterior cover and localized smart limbs with embedded reflex circuits for decentralized actuator response. The mechanical hands execute multi-axis tactile grips required for handling rigid and semi-flexible components.
Operations at the 2,300-square-meter facility focus on component loading, bottle filling, packaging handling, and material manipulation across multi-industry trials. Companies test cognitive robot arms, mobile manipulators like MiPA, and humanoid units against specific line parameters prior to factory deployment. The platform was also exhibited at the NVIDIA GTC event in Berlin on 22 October 2026.
Operational Impact
By substituting manual programming routines with physical AI trained on empirical force and sensor data, the architecture shortens commissioning cycles for complex automated tasks. Process stability and grip precision improve through distributed reflex computing, allowing machines to adapt to positional misalignments in real time. The Munich site serves as the validation blueprint for planned development centers across Europe, North America, and Asia.
Edited by Natania Lyngdoh, Induportals editor, with AI assistance.
www.neura-robotics.com